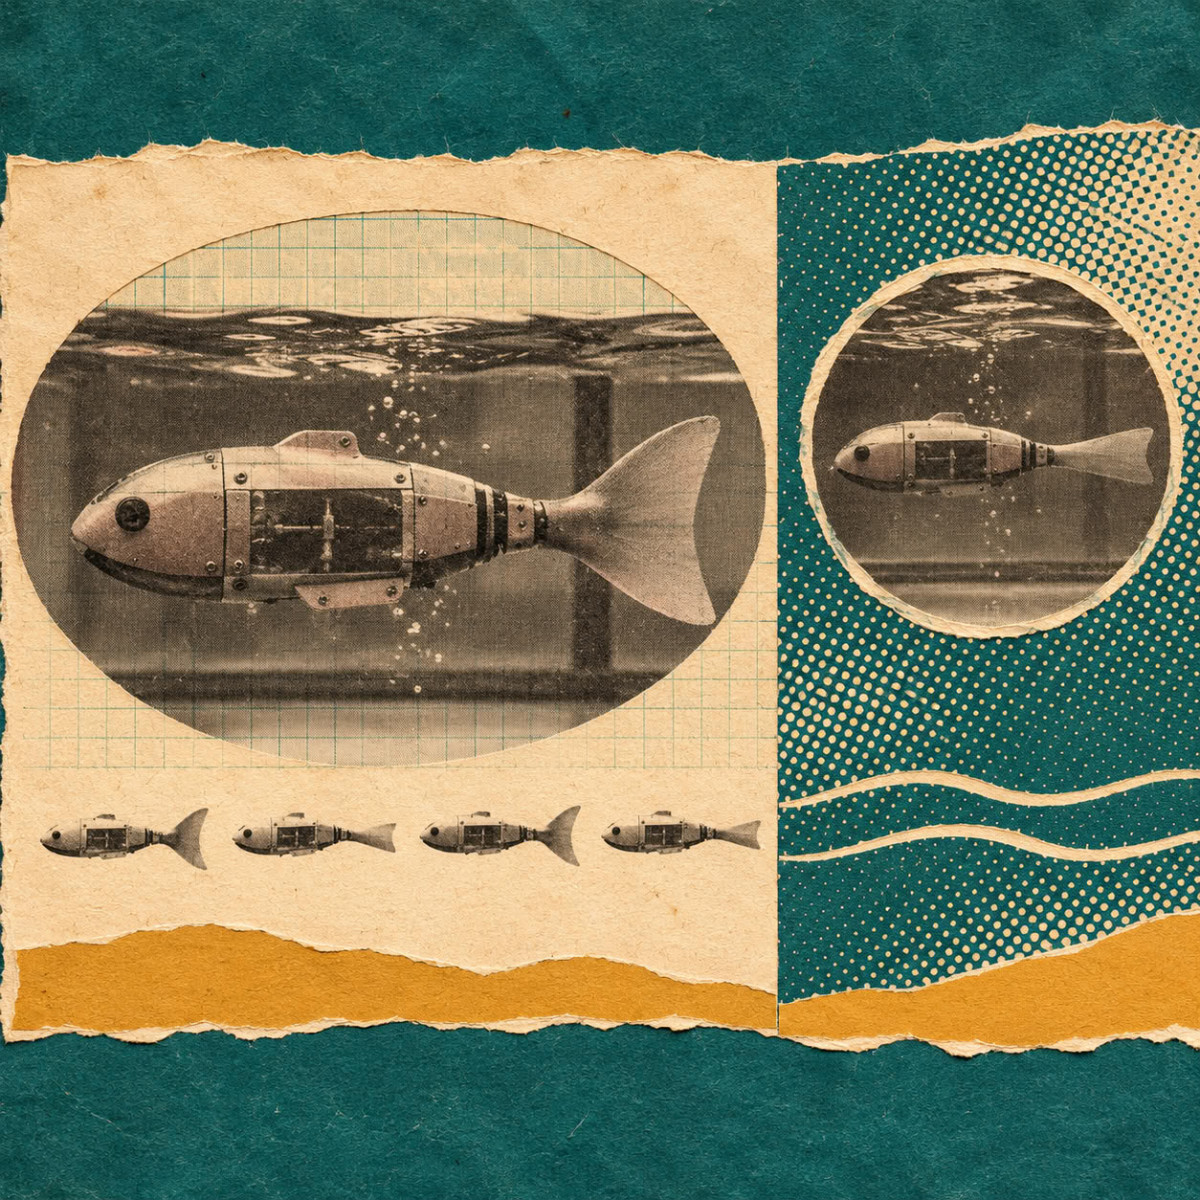

An international team comprising EPFL (Switzerland), Duke University (USA), and Instituto Superior Técnico (Portugal) has studied intermittent, or ‘burst-and-glide’, swimming using a robot inspired by the zebrafish. According to the researchers, this swimming style, which alternates propulsion phases with gliding phases, consumes less energy than continuous swimming.
Improving energy performance allows for extending a robot’s operating time and reducing its battery load. Nature has already explored this path: intermittent swimming is a widespread behavior among aquatic organisms of very varied sizes, including zebrafish larvae, red-nose tetras, koi carp, and even whales. This swimming mode alternates short phases of active body and tail undulation with phases of passive gliding, the body remaining straight and streamlined.
A robot inspired by the zebrafish
To study this mechanism, the researchers developed a robotic platform inspired by larval zebrafish (ZBot). The robot is scaled 200 times larger than the larva, with a length of 80 cm and a mass of 2.8 kg. Its flexible tail comprises six segments driven by servomotors, while its head houses a central controller acting as a nervous system, high-precision cameras, and real-time wattmeters.
The teams from EPFL and Duke University also built a neurocomputational model simulating the zebrafish’s neural circuits. It relies on central pattern generators (CPGs), which produce rhythmic undulation signals, and a ‘burst gate’ module. The latter accumulates input signals and only triggers tail undulation from a set threshold, reproducing the natural ‘active burst, passive glide’ rhythm. By adjusting the frequency, tail oscillation amplitude, and threshold of this module, ZBot reproduces several larval gaits: slow straight swimming, regular turns, and ‘J-turns’. The model also enabled the reproduction of the vision-guided optomotor response in the robot and in a digital twin, simZFish.
The role of viscosity
The researchers also wondered whether this energy advantage persisted in more viscous fluids, such as those where very small organisms move. The Reynolds number, a dimensionless quantity, compares the importance of inertial forces and viscous forces in a flow. Large animals, like whales, swim at high Reynolds numbers, while small zebrafish larvae operate in an intermediate regime, more strongly influenced by viscous drag.
To mimic organisms of different sizes, the team modified the liquid’s viscosity. The moderately viscous fluid, with a viscosity of 213.9 cP, is compared to a fruit topping sauce, and the highly viscous fluid, of 457.0 cP, to a standard makeup remover oil. In the latter, the distance traveled by ZBot is only 1/30th of that achieved in normal water. Conversely, viscosity has little influence on turning ability: the turning angle per burst is about 60 degrees in normal water and remains 45 degrees in the highly viscous liquid.
Two hypotheses on energy savings
The experiments confirmed that intermittent swimming reduces energy consumption at all achievable speeds, at both high and low Reynolds numbers. In return, the maximum speed achieved is about 60% of that of continuous swimming, due to the limited cycle of bursts and glides.
The most commonly proposed hypothesis attributes this gain to the straight posture of the tail during gliding, which would reduce drag. The team proposes another explanation, termed ‘actuator efficiency’: intermittent swimming would allow the robot’s servomotors, or the fish’s muscles, to operate in more efficient regimes. According to the researchers, both servomotors and fish muscles follow an inverted U-shaped efficiency curve, optimal only under moderate load. At low speed, continuous swimming keeps them in an under-loaded and inefficient state, whereas the burst-glide cycle brings the load closer to this optimal range.
The authors finally believe that these results can guide the design of underwater robots, which could adopt an intermittent mode for low- or medium-speed cruising, and a continuous mode for high-speed emergency maneuvers.
